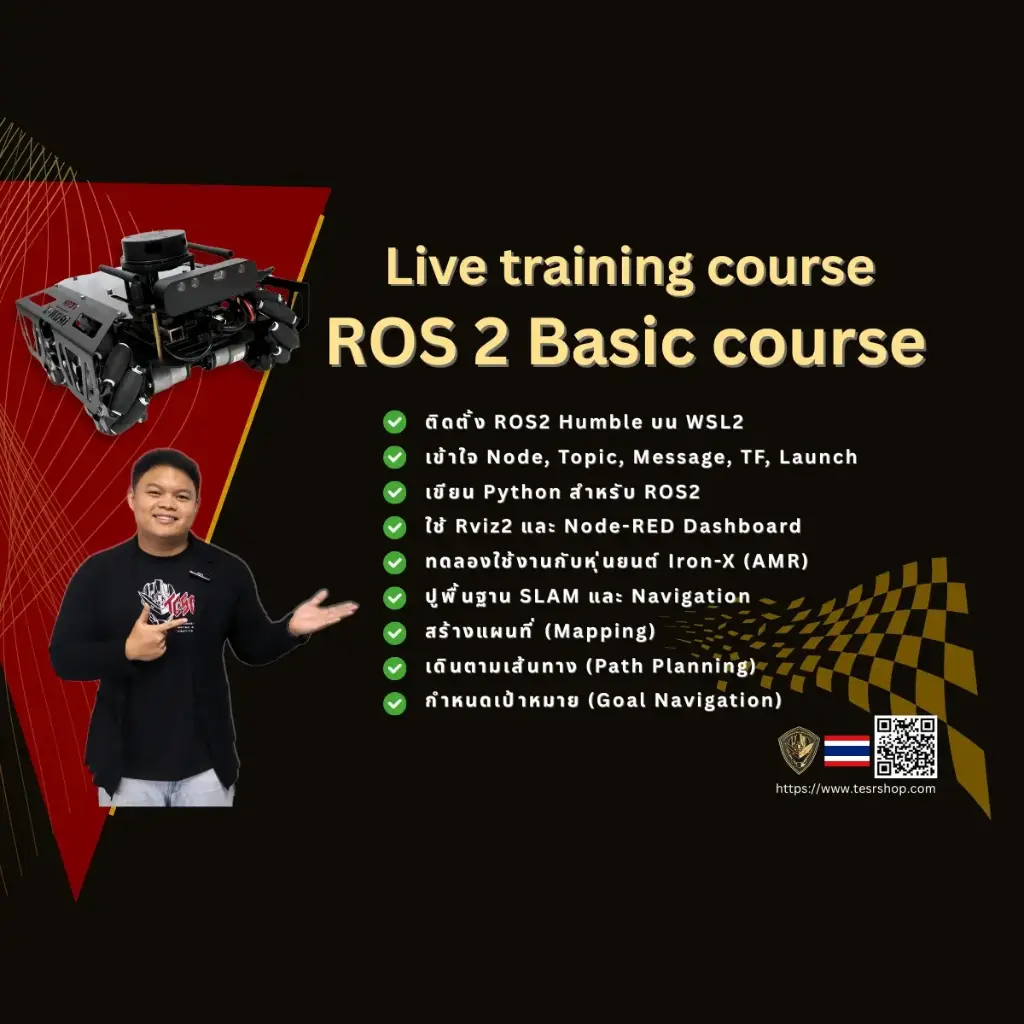
ROS 2 Basic for Mobile Robot (iron-x)
Online course for who has the iron-x in your hands.
คอร์สส่วนตัว
กรุณา ลงชื่อเข้าใช้ เพื่อติดต่อผู้รับผิดชอบ
| รับผิดชอบ | Anoney Potter |
|---|---|
| อัปเดตครั้งล่าสุด | 01/11/2026 |
| เวลาเสร็จสิ้น | 6 ชั่วโมง 12 นาที |
| สมาชิก | 197 |
พื้นฐาน
Robotics
ROS
iron-x
-
Material5บทเรียน 10 นาที
-
code and script
-
Documents
-
iron-x LabSheet Humble version
-
iron-x LabSheet Jazzy version
-
ดูตัวอย่าง
-
-
VDO Content ROS 2 Humble12บทเรียน 2 ชม. 36 นาที
-
ดูตัวอย่าง 10 xp
-
2. ROS 2 Installation in WSL
-
3. Introduction to ROS
-
4. introduction to iron-x
-
5. Linux Basic Commands
-
6. ROS 2 PC and Robot Network setting
-
7. Python Chatter
-
8. iron-x JoyStick and Keyboard
-
9. iron-x SLAM and Navigation
-
10.1 LaserScan RPLidar
-
ดูตัวอย่าง
-
11. Node-Red contrib ROS 2 Humble
-
-
VDO Content ROS 2 Jazzy17บทเรียน 3 ชม. 13 นาที
-
1. Introdction to ROS 2
-
2. WSL 2
-
3. Install ROS 2 Jazzy on PC site
-
4. Linux Basic Commands
-
5. ROS2ConceptByTurtlesim
-
6. iron-xsimulationOnGAZEBO
-
7. Introduction-to-iron-x
-
8. ROS2 PC&Robot Network setting
-
9. iron-x JoyStick Keyboard
-
10. LaserScan RPLidar
-
11. imu data
-
12. Python Chatter
-
13. Remote Desktop Using VNC
-
14. iron-x SLAM and Navigation
-
15.1 Node-Red contrib ROS2 Jazzy(TESR Studio Pro)
-
15.2 iron-x Gen II Payload IO - EP1 การใช้งาน IO
-
15.3 iron-x Gen II Payload IO - EP2 IO + Navigation
-
-
Optional1บทเรียน 13 นาที
-
ดูตัวอย่าง
-
-
Link สินค้า2บทเรียน
-
ดูตัวอย่าง
-
ดูตัวอย่าง
-
เรียนจบแล้วทำอะไรได้
- ติดตั้ง ROS 2 (Humble และ Jazzy) บน Windows ผ่าน WSL2 และใช้คำสั่ง Linux พื้นฐานได้
- เข้าใจแนวคิดของ ROS 2 ผ่าน Turtlesim และเขียนโปรแกรม Python Chatter
- ตั้งค่าเครือข่ายระหว่างคอมพิวเตอร์กับหุ่นยนต์ และควบคุม iron-x ด้วย Joystick หรือคีย์บอร์ด
- สร้างแผนที่ด้วย SLAM และสั่งหุ่นยนต์เดินทางอัตโนมัติด้วย Navigation
- อ่านข้อมูลจาก LiDAR (RPLidar) และ IMU, จำลองหุ่นยนต์ใน Gazebo และเชื่อม Node-RED กับ ROS 2
- ใช้งาน Payload IO ของ iron-x Gen II ร่วมกับ Navigation
เหมาะกับใคร
- ผู้ที่มีหุ่นยนต์ iron-x และต้องการใช้งานให้เต็มความสามารถ
- นักศึกษา วิศวกร และผู้สอนที่ต้องการเริ่มต้น ROS 2 กับหุ่นยนต์จริง
สิ่งที่ควรมีก่อนเรียน
- คอมพิวเตอร์ Windows 10 หรือ 11
- หุ่นยนต์ iron-x สำหรับฝึกปฏิบัติ
- ไม่จำเป็นต้องมีพื้นฐาน ROS มาก่อน
ในคอร์สมีอะไร
- 37 บทเรียน รวมประมาณ 6.2 ชั่วโมง
- วิดีโอบทเรียนทั้งเวอร์ชัน ROS 2 Humble และ Jazzy
- LabSheet iron-x ทั้งเวอร์ชัน Humble และ Jazzy และคู่มือคำสั่ง ROS 2 Basic
- ไฟล์โค้ดและเอกสารประกอบสำหรับดาวน์โหลด